Exposure-integrated
motion blur
Analytically evaluate each projected Gaussian's exposure-time integral using the error function, under a linear screen-space motion approximation.
1 RAI Institute, United States2 Seoul National University, South Korea
* Co-corresponding authors

Abstract
Sharp renderings. Compact maps.
Online reconstruction.
Online 3D Gaussian Splatting (3DGS) is emerging as a practical representation for robotics. Real-world deployment, however, brings two challenges: rapid robot motion produces blurry observations that corrupt geometry and camera poses, while continuous mapping can grow the number of Gaussians without bound.
RoMo-GS addresses both. Instead of averaging multiple discrete sub-frames, we analytically integrate each projected Gaussian over the exposure interval, yielding O(1) complexity per Gaussian. A Hessian-based pruning score controls map growth, while joint Adam optimization refines poses, velocities, and Gaussians, followed by an online Levenberg–Marquardt step on the Gaussians.
Across public and self-collected datasets, RoMo-GS achieves competitive rendering quality with offline deblurring methods at substantially lower running time, and retains about 20% fewer Gaussians than the online MODP baseline at comparable quality.
Watch the system
Method
RoMo-GS combines exposure-integrated motion blur, joint optimization, and online density control in a tracker-agnostic mapping backend.
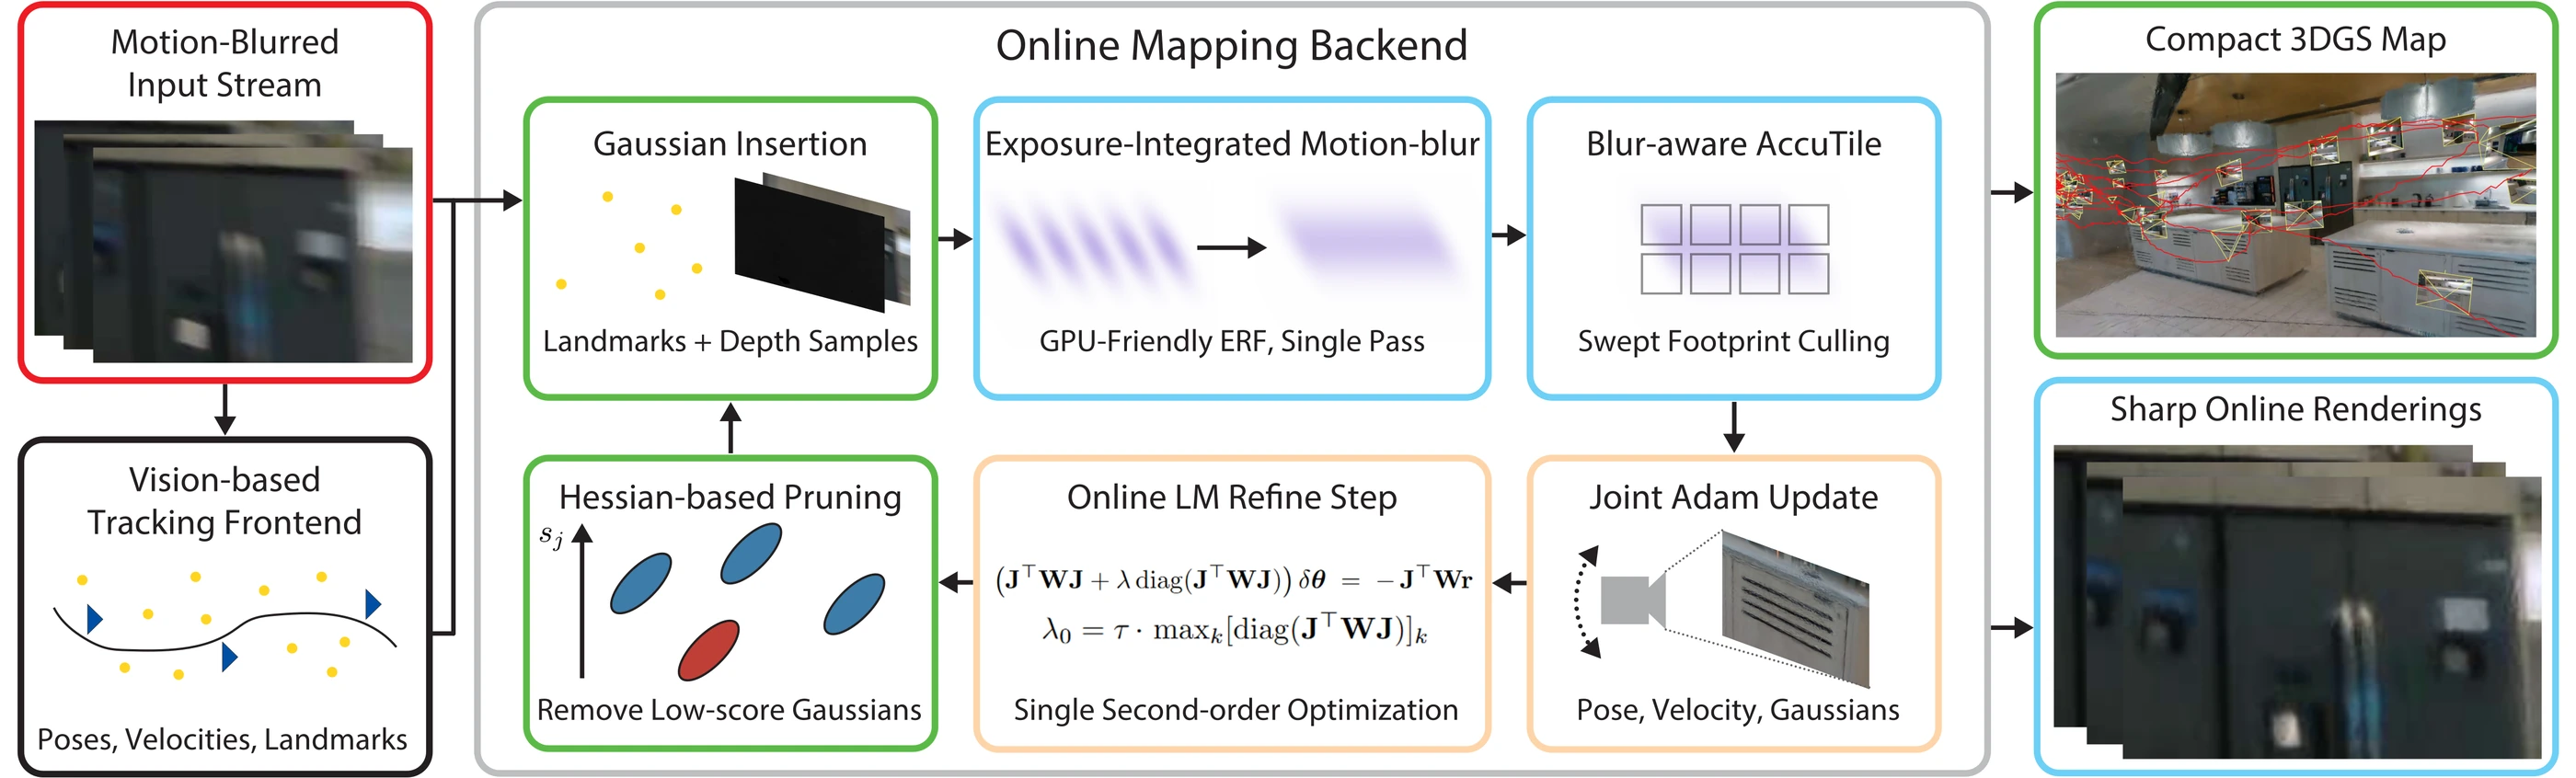
Analytically evaluate each projected Gaussian's exposure-time integral using the error function, under a linear screen-space motion approximation.
Render a motion-blurred frame in one CUDA rasterization pass. The per-Gaussian cost stays constant instead of growing with the number of temporal samples.
Jointly refine pose, velocity, and Gaussians with Adam, apply an online LM step to the map, and remove redundant Gaussians with a Hessian-based score.
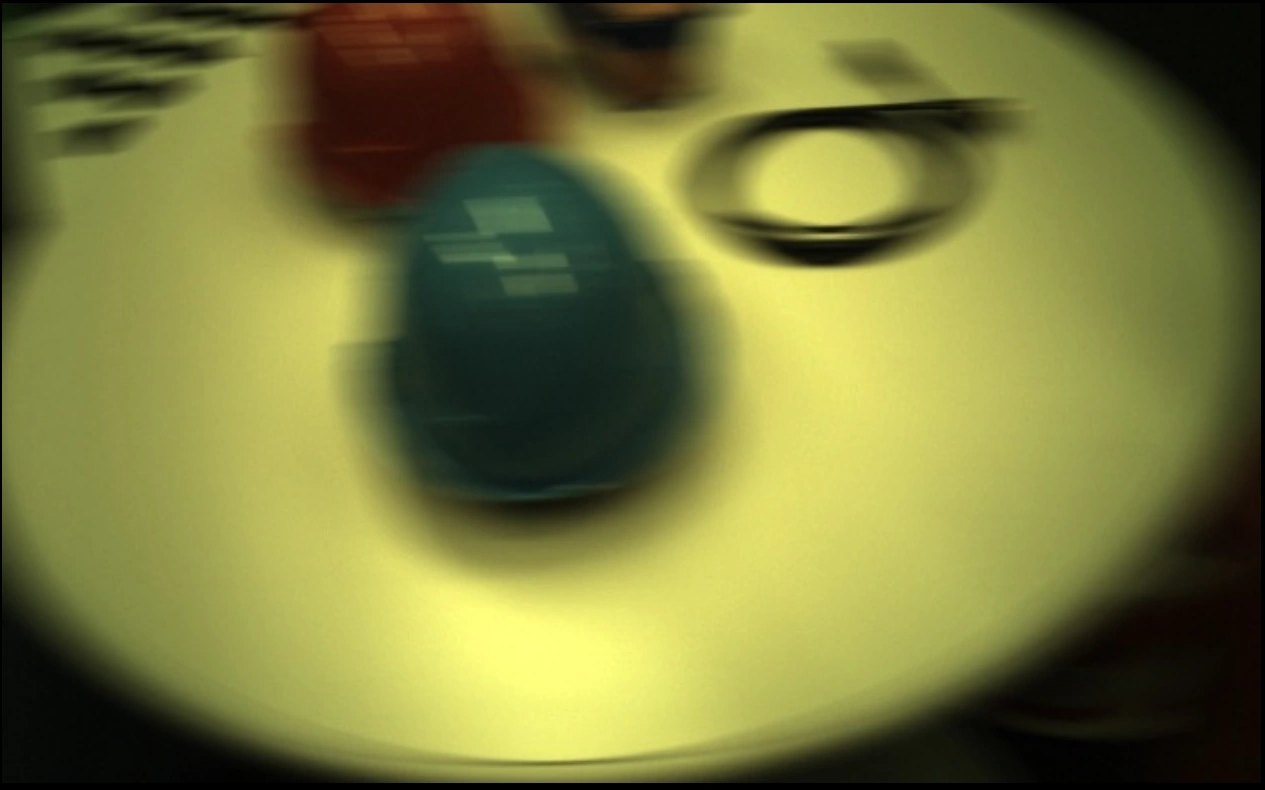
 RoMo-GSBlurry input
Citation
@article{jung2026romo,
  title={RoMo-GS: Efficient Online 3D Gaussian Splatting for Robot Mapping via Exposure-Integrated Motion Blur},
  author={Jung, Sangwoo and Deng, Di and Fu, Jiahui and Herlant, Laura and Kim, Ayoung and Hu, Yafei},
  journal={arXiv preprint arXiv:2610.24605},
  year={2026}
}We thank ETH Zürich for providing experimental space for real-world testing, data collection, and demo video filming.
 Seoul National UniversityDepartment of Mechanical Engineering